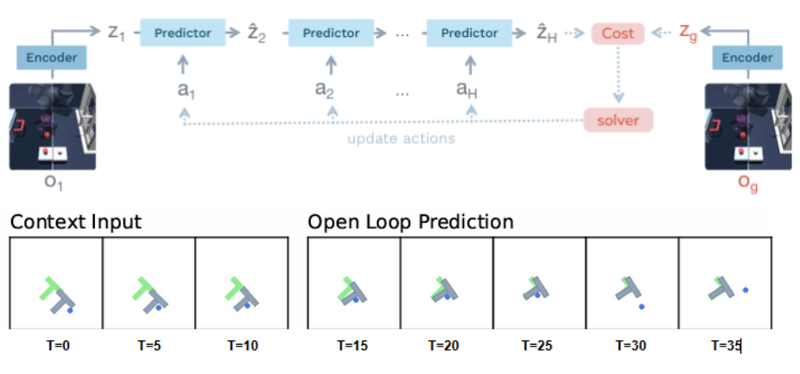
In this project, we take LeWorldModel (LeWM), a JEPA-based world model that predicts environment dynamics in latent representation space and plans by simulating candidate action sequences, as our starting point. We study three limitations in its planning phase. First, we ask whether LeWM learns transferable latent dynamics and whether it can recover optimal plans when key environmental factors change. Second, we extend LeWM to multi-agent settings, where another agent may act cooperatively, neutrally, or adversarially with respect to the primary agent’s goal. Third, because LeWM relies on the Cross Entropy Method (CEM) for trajectory optimization, we investigate whether alternative search or optimization methods can improve long-horizon planning at comparable computational cost.
Team: Tahmid Hossain Jit, Sami Rashid, MD Raqibul Islam, MD Mubtasim Ahasan, AKM Mahbubur Rahman, PhD, Amin Ahsan Ali, PhD